The current circle kernels use regular symmetric sectors and specific internal and external triangles. Their convergence results assume exact arithmetic and fixed radius.
What Requires Separate Verification
Floating-point and fixed-point stability, computational efficiency, general curves, nonconvex geometry, holes, adaptive sampling, and three-dimensional constructions require their own specifications and evidence.
Refinement
Increasing geometric resolution does not guarantee increasing numerical accuracy indefinitely. Cancellation, quantisation, and underflow or overflow may limit an implementation.
Historical Methods
Cartesian projection and trapezoidal methods have different sampling and endpoint behaviour. Their error rates must not be inferred from the angular kernel proofs.
Research Claims
The existence of a coherent formulation and a valid error proof does not establish original authorship of a local weighting or superiority over alternative implementations.
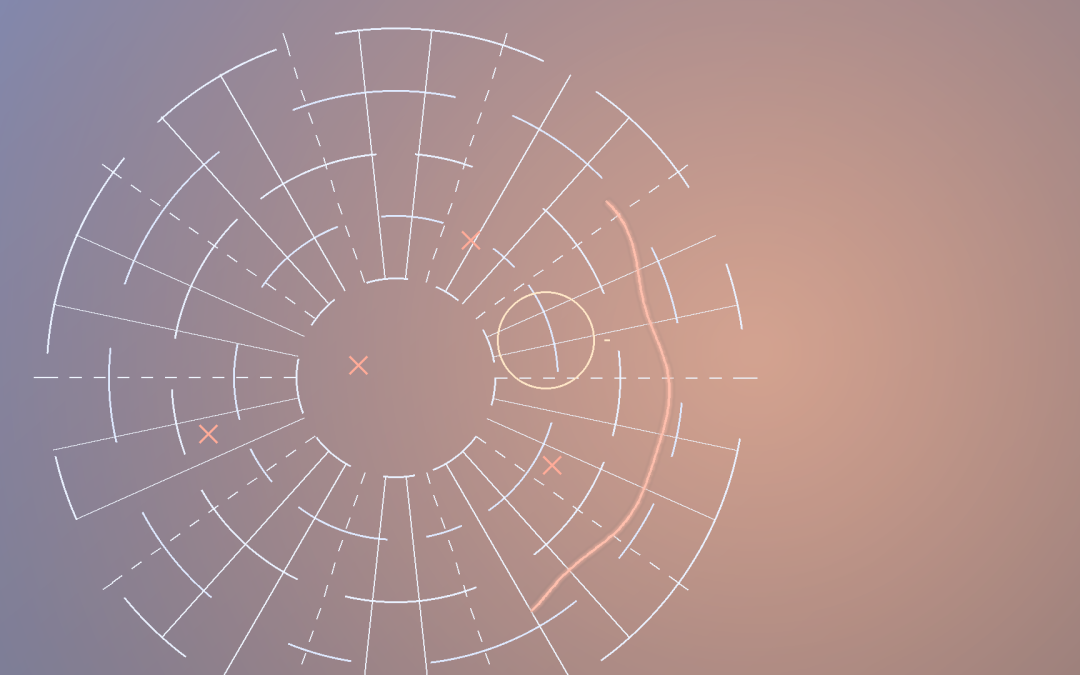
We describe a continuous model that interprets GRG’s inside-out construction as integral curves of a center-seeded field on a domain Ω ⊂ ℝ². Let the seed be s ∈ Ω. For any point x ≠ s define the unit radial direction er(x) = (x−s)/‖x−s‖ and a tangential direction et(x) orthogonal to er. The guidance field blends radial and tangential components.
Radial Guidance Field
The model uses a field F: Ω\\{s} → ℝ² with radial bias
Each turn-angle u ∈ [0,1) selects an initial direction, producing a family of trajectories that reach the boundary. The discrete GRG construction samples these trajectories at uniform steps in turns.
Well-posedness
Existence & Uniqueness. If F is locally Lipschitz on Ω\\{s} then trajectories starting away from the seed have local existence and uniqueness while they remain in that domain. Global continuation and boundary arrival require additional hypotheses.
Termination. Trajectories stop when they hit ∂Ω. Dirichlet-type constraints prescribe a target boundary, while Neumann-type constraints control flux through ∂Ω.
Stability to Perturbations
If F has Lipschitz constant L, perturbing the seed by ε yields trajectories with deviation bounded by
Hole guards choose weights that vanish across cut-loci to prevent ambiguous paths.
Discrete Connection
Sampling each trajectory at uniform steps in turns yields the GRG primitives used for chord sums and radial strips. The continuous model justifies convergence as resolution increases. With turns-first sampling and dyadic refinement, the discrete GRG primitives converge monotonically as b increases.
Center-seeded field with trajectories to the boundary, auxiliary seed for a hole, and example paths.
Practical Defaults
Field coefficients.a(x)=1 near the seed, tapering to maintain stable speed; b(x) small and smooth to avoid spirals.
Adaptive control. Increase samples where the curvature proxy exceeds a threshold; cap Δu.
Refinement (dyadic). Use the dyadic level b ∈ ℕ≥0 with N = 2^b samples and step Δu = 2^{-b}; increasing b yields monotone refinement.
Reconstruction. Quarter symmetry reconstructs the full figure; multi-seed blending covers non-simply connected domains.
To provide the best experiences, we use technologies like cookies to store and/or access device information. Consenting to these technologies will allow us to process data such as browsing behavior or unique IDs on this site. Not consenting or withdrawing consent, may adversely affect certain features and functions.
Functional
Always active
The technical storage or access is strictly necessary for the legitimate purpose of enabling the use of a specific service explicitly requested by the subscriber or user, or for the sole purpose of carrying out the transmission of a communication over an electronic communications network.
Preferences
The technical storage or access is necessary for the legitimate purpose of storing preferences that are not requested by the subscriber or user.
Statistics
The technical storage or access that is used exclusively for statistical purposes.The technical storage or access that is used exclusively for anonymous statistical purposes. Without a subpoena, voluntary compliance on the part of your Internet Service Provider, or additional records from a third party, information stored or retrieved for this purpose alone cannot usually be used to identify you.
Marketing
The technical storage or access is required to create user profiles to send advertising, or to track the user on a website or across several websites for similar marketing purposes.